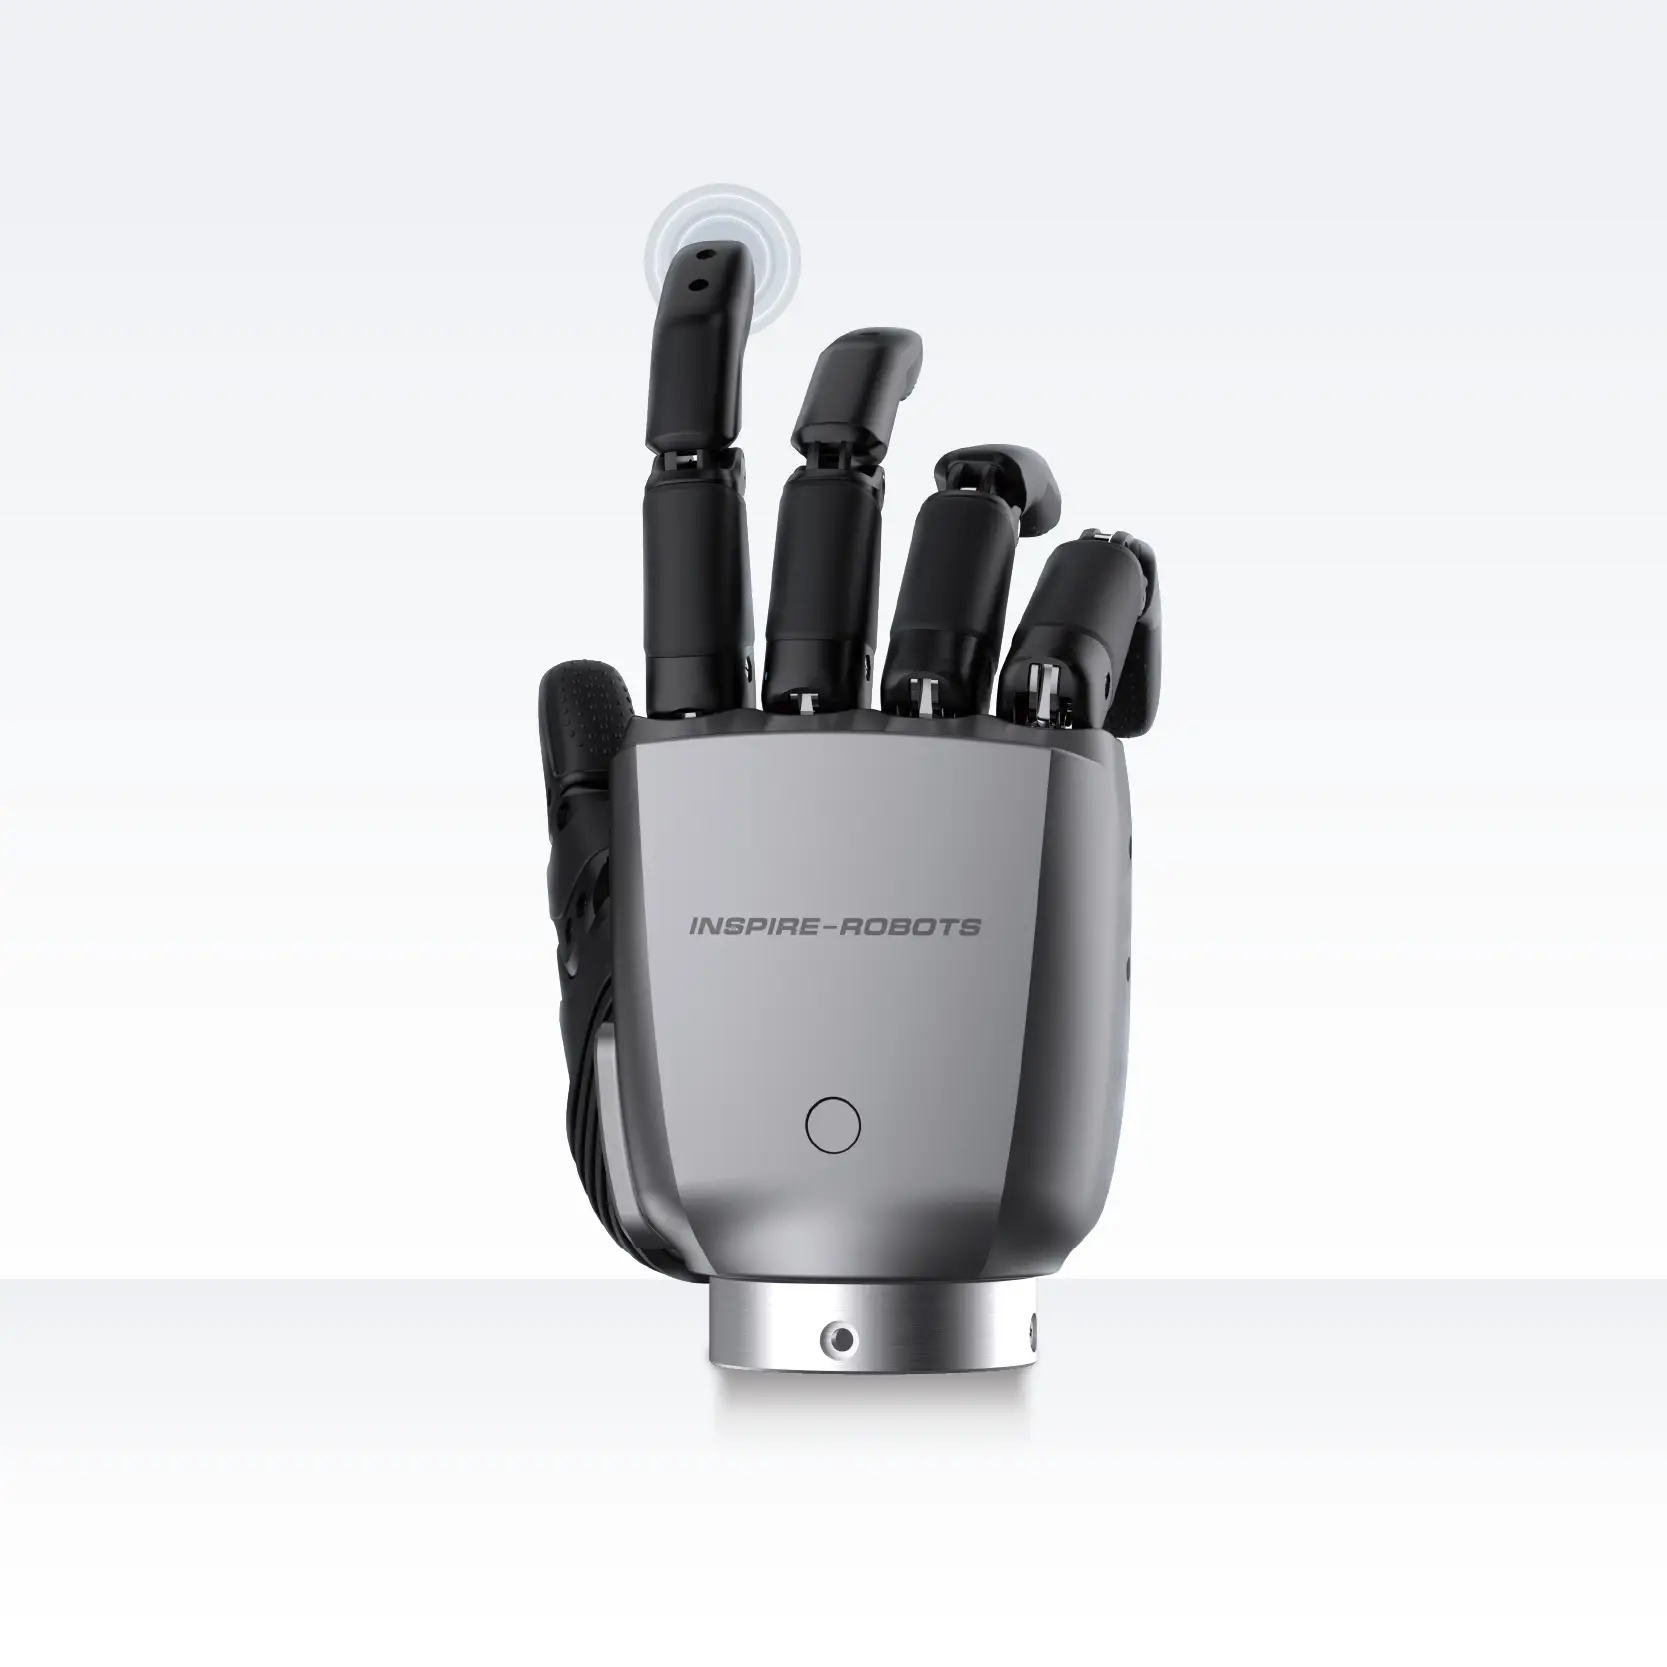
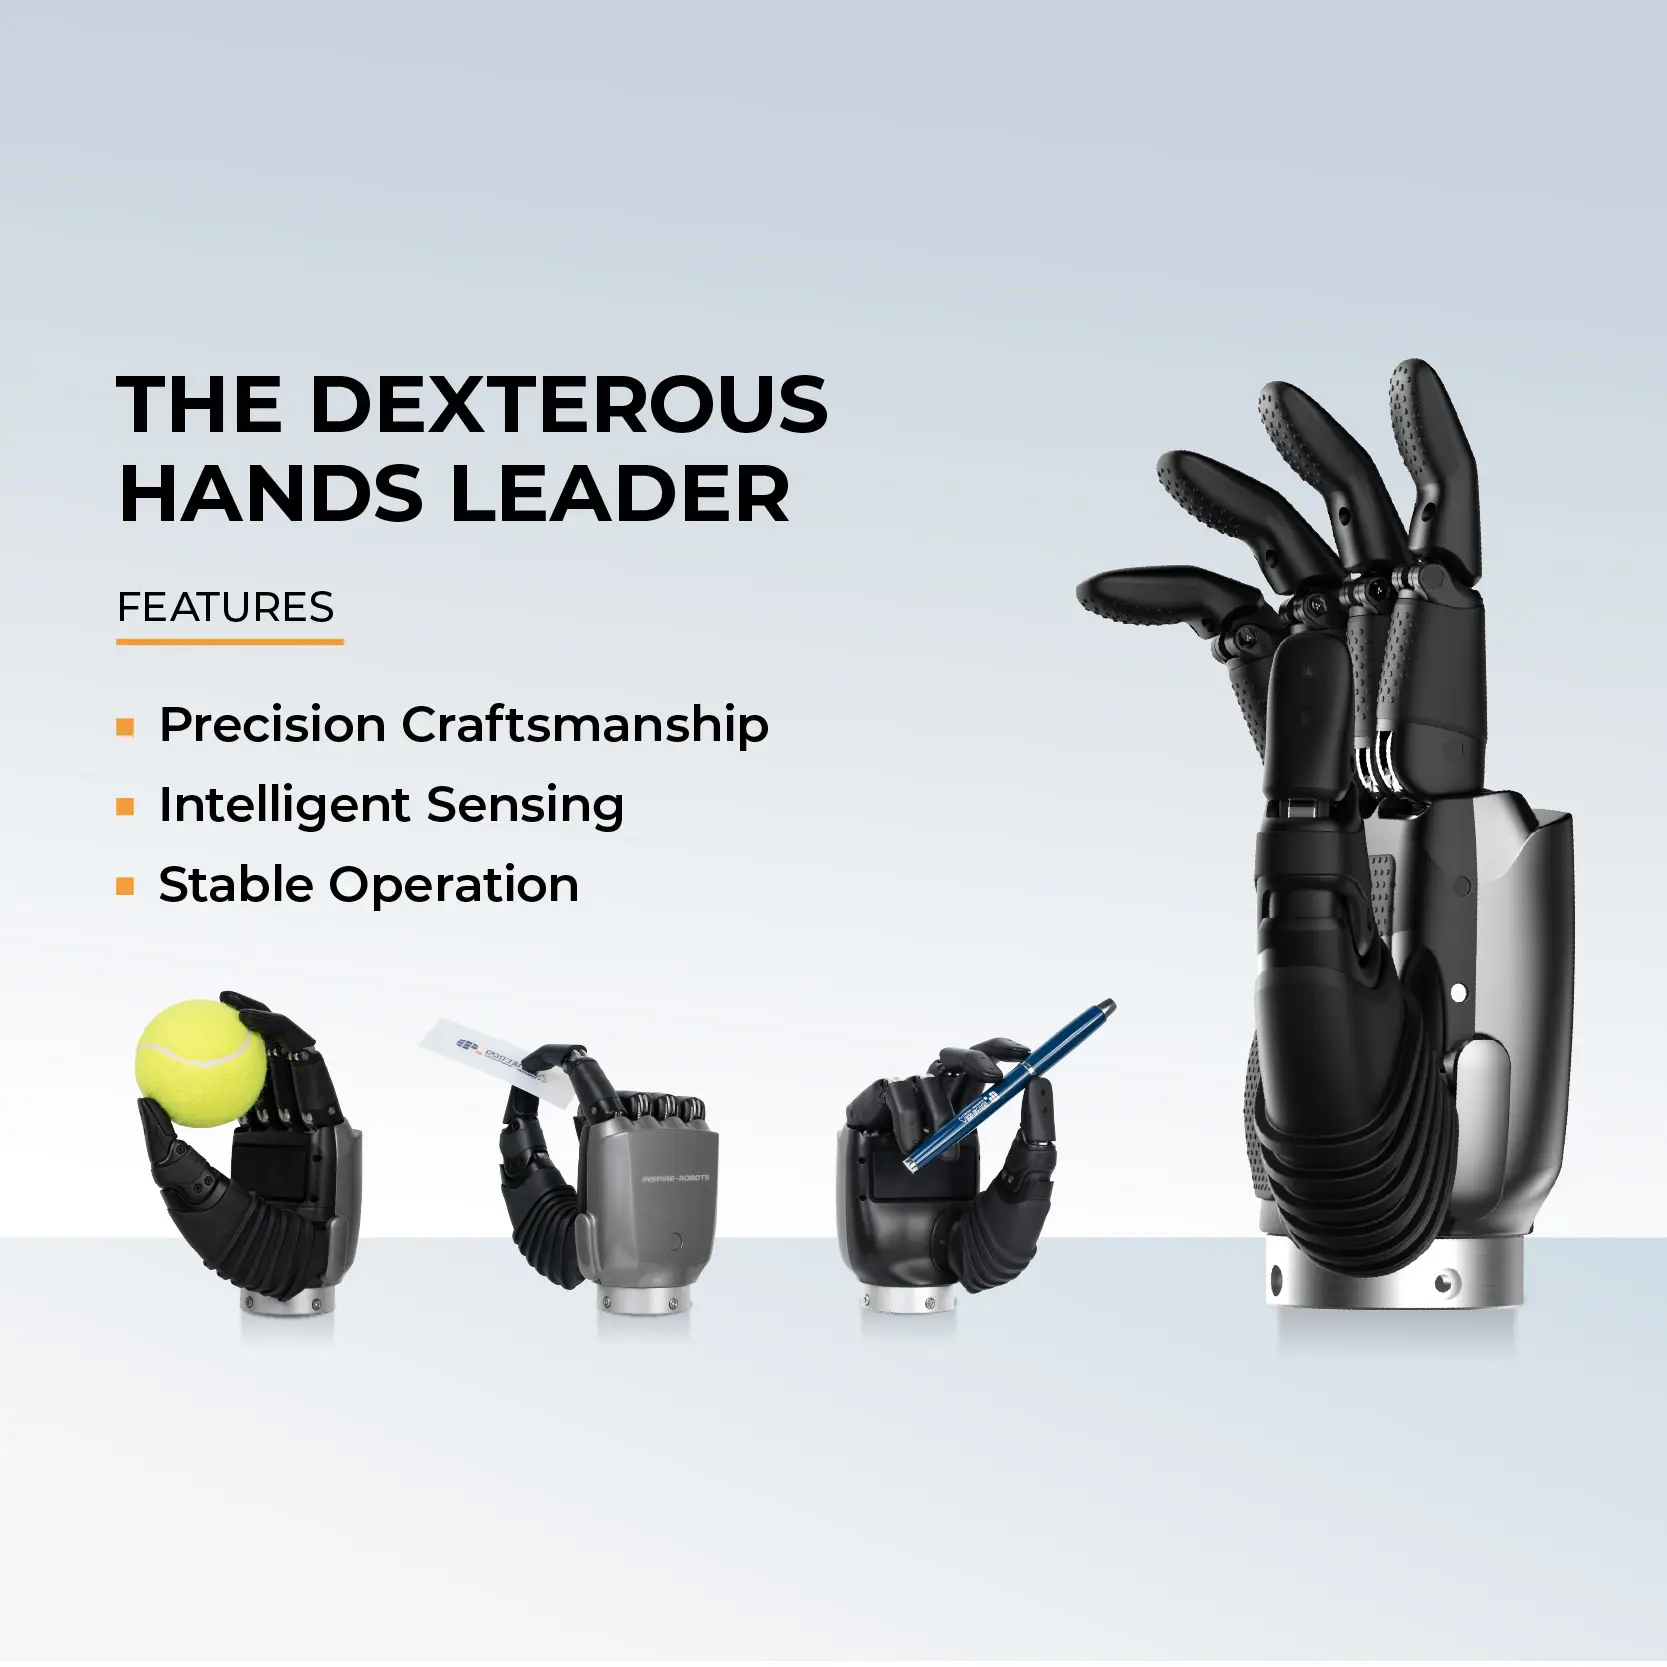
RH56F1 official English product information from INSPIRE ROBOTS.
Standard specifications
| gripper type | Five-finger dexterous hand with all-metal integrated skeleton |
|---|---|
| grip force n | Thumb fingertip force ≥15 N; fingertip force ≥10 N |
| finger count | 5 |
| repeatability mm | ±0.2 mm |
| weight kg | 615±10 g (without tactile sensors); 630±10 g (with tactile sensors) |
| communication protocol | EtherCAT + RS485; EtherCAT + CAN FD variants |
| supply voltage v | 24–48 V |
Technical extensions
Official table: 6 DOF, 12 joints; 1 kHz real-time communication; 0.1 N force resolution; tactile variant has eight tactile sensors, 30 N sensor range and 5%FS accuracy; thumb rotation 60–180° at >155°/s; thumb flexion >37°/s and four-finger flexion >107°/s; closing time ≤0.8 s; 30 kg passive payload stated in the official page narrative.