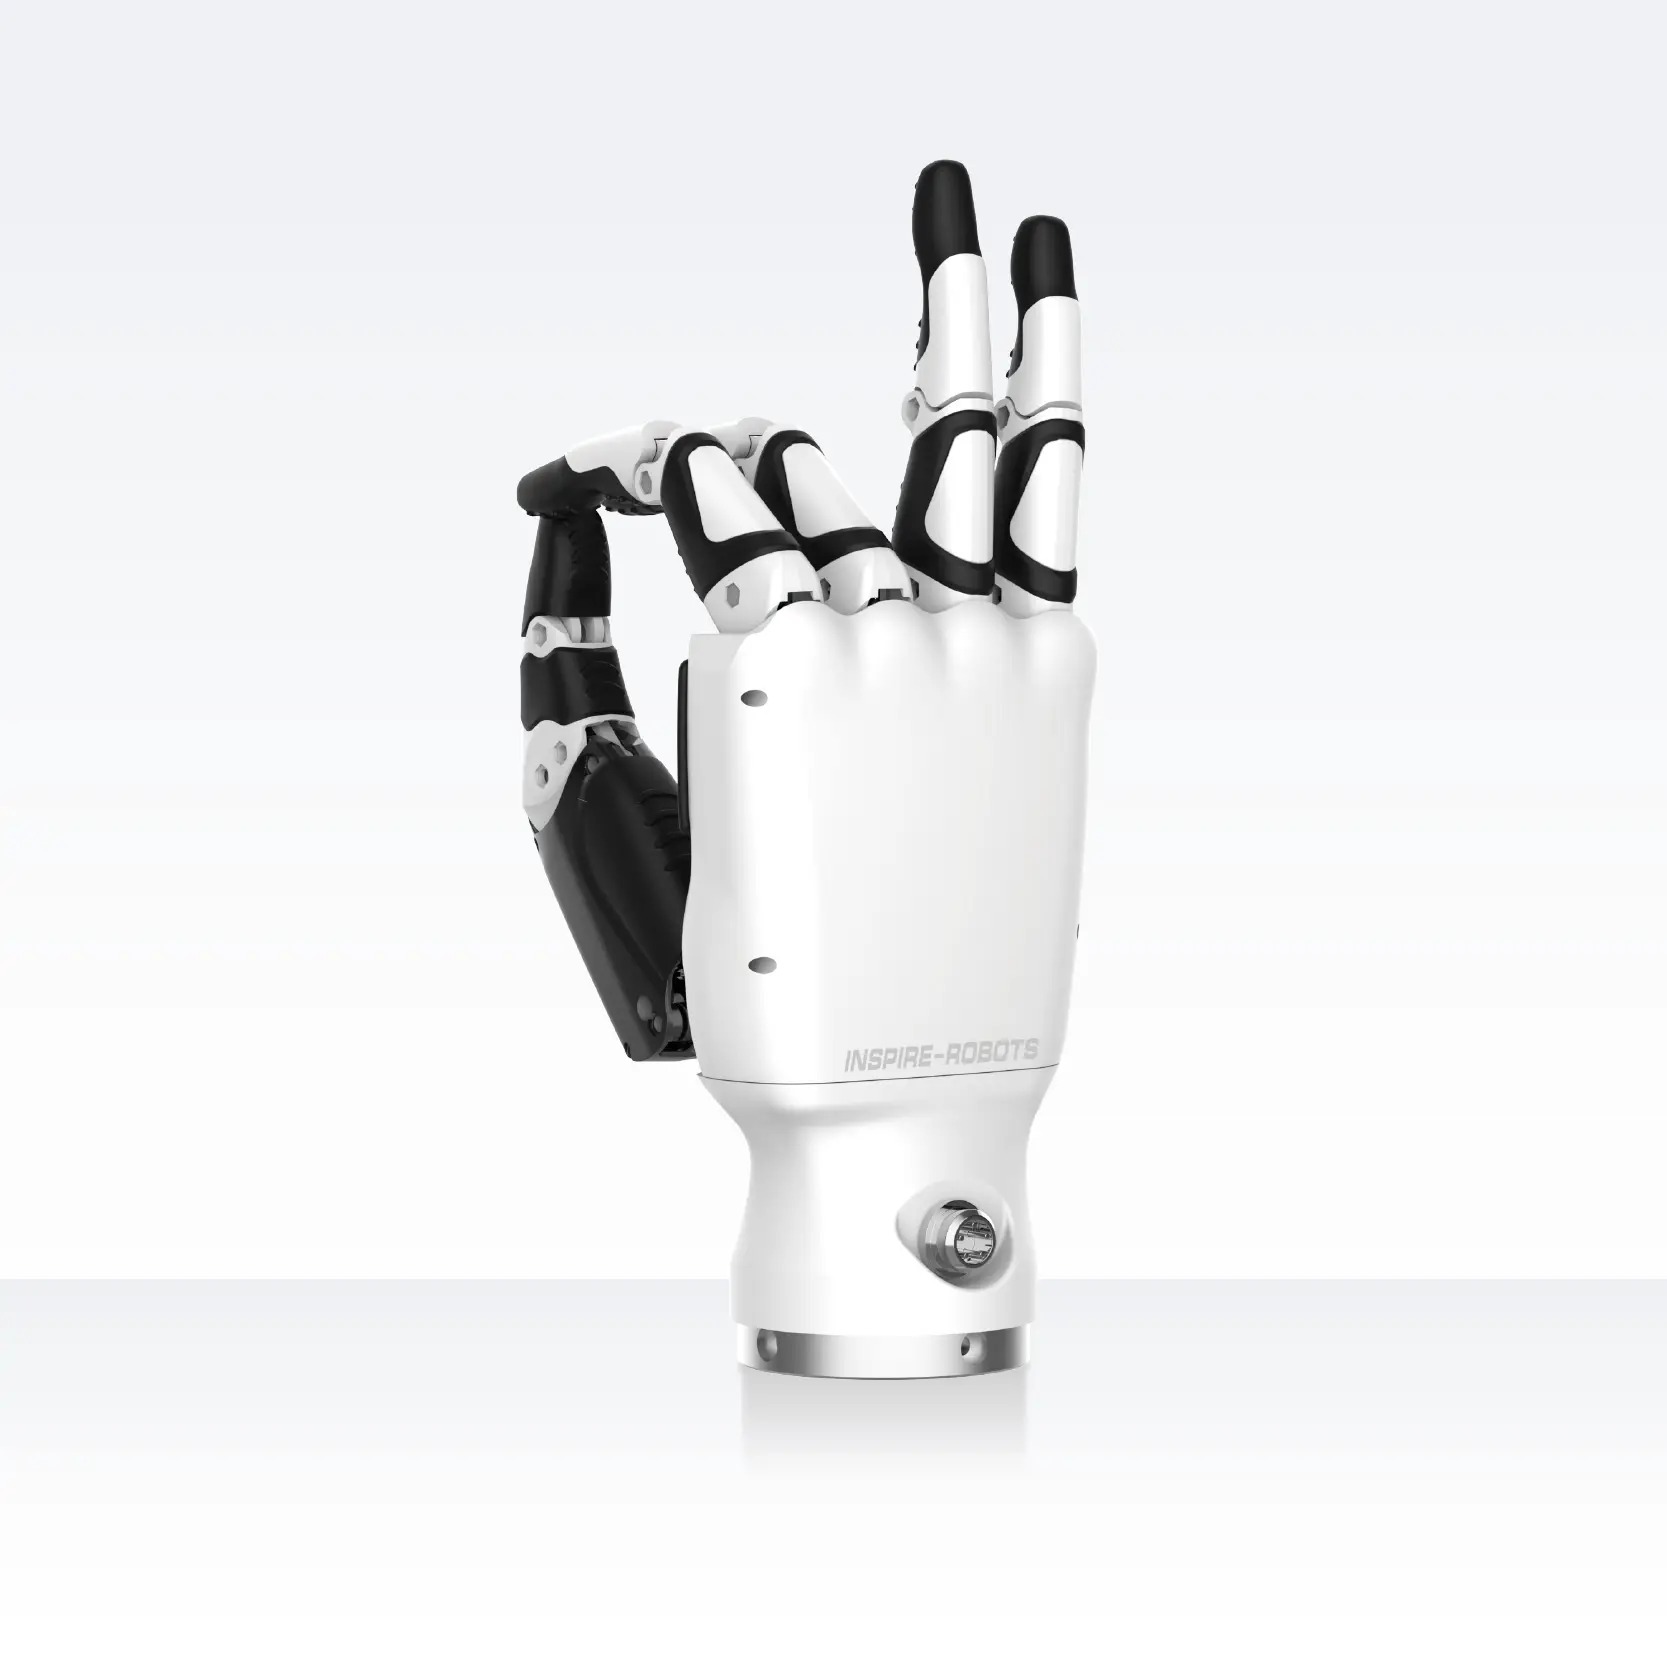
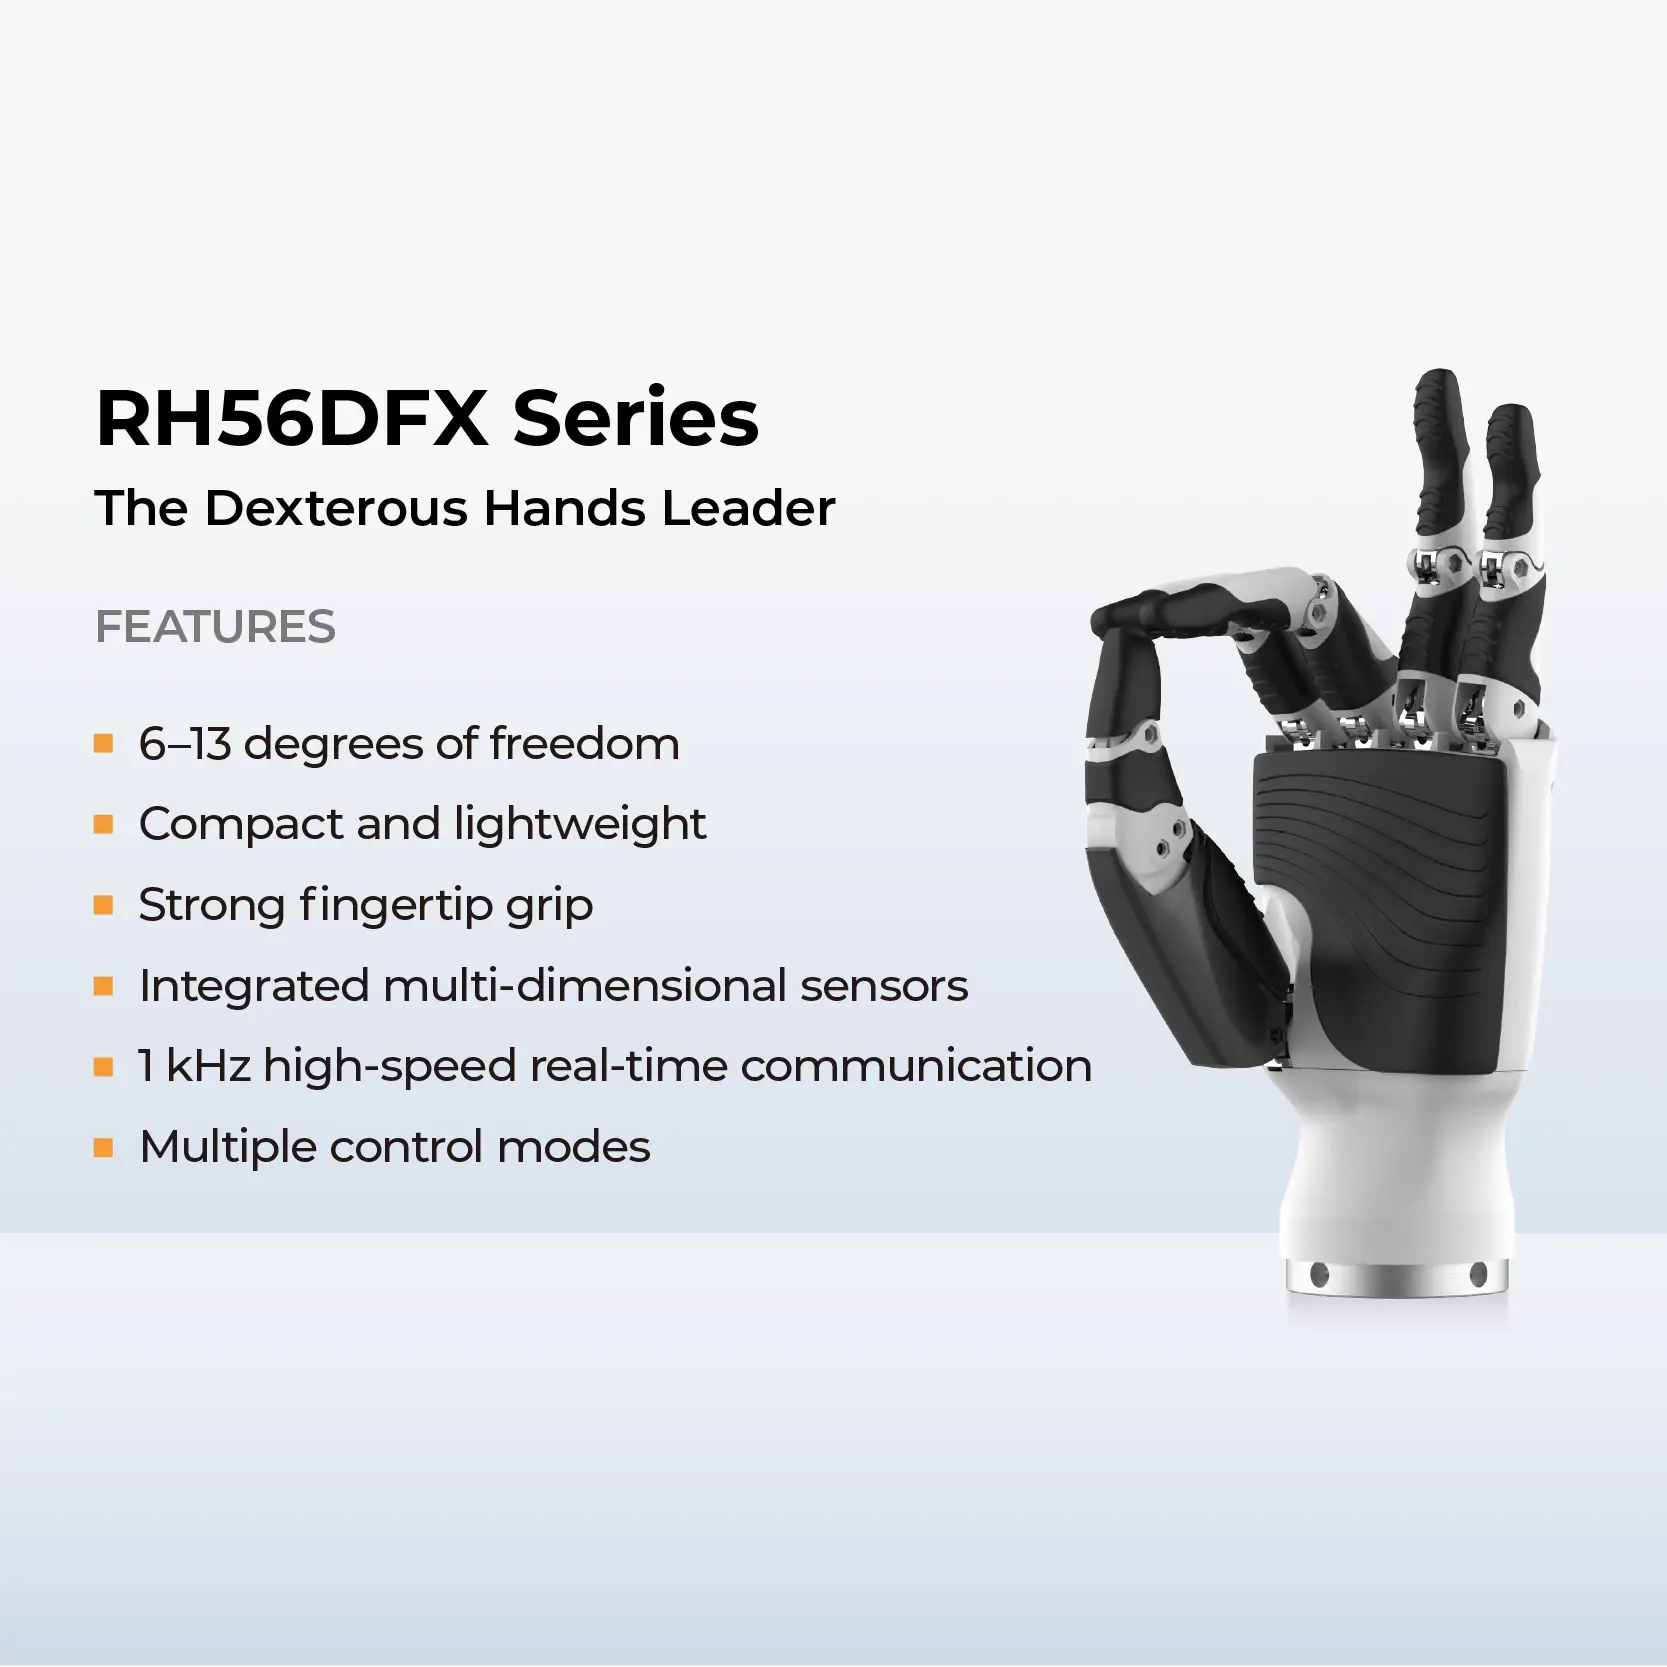
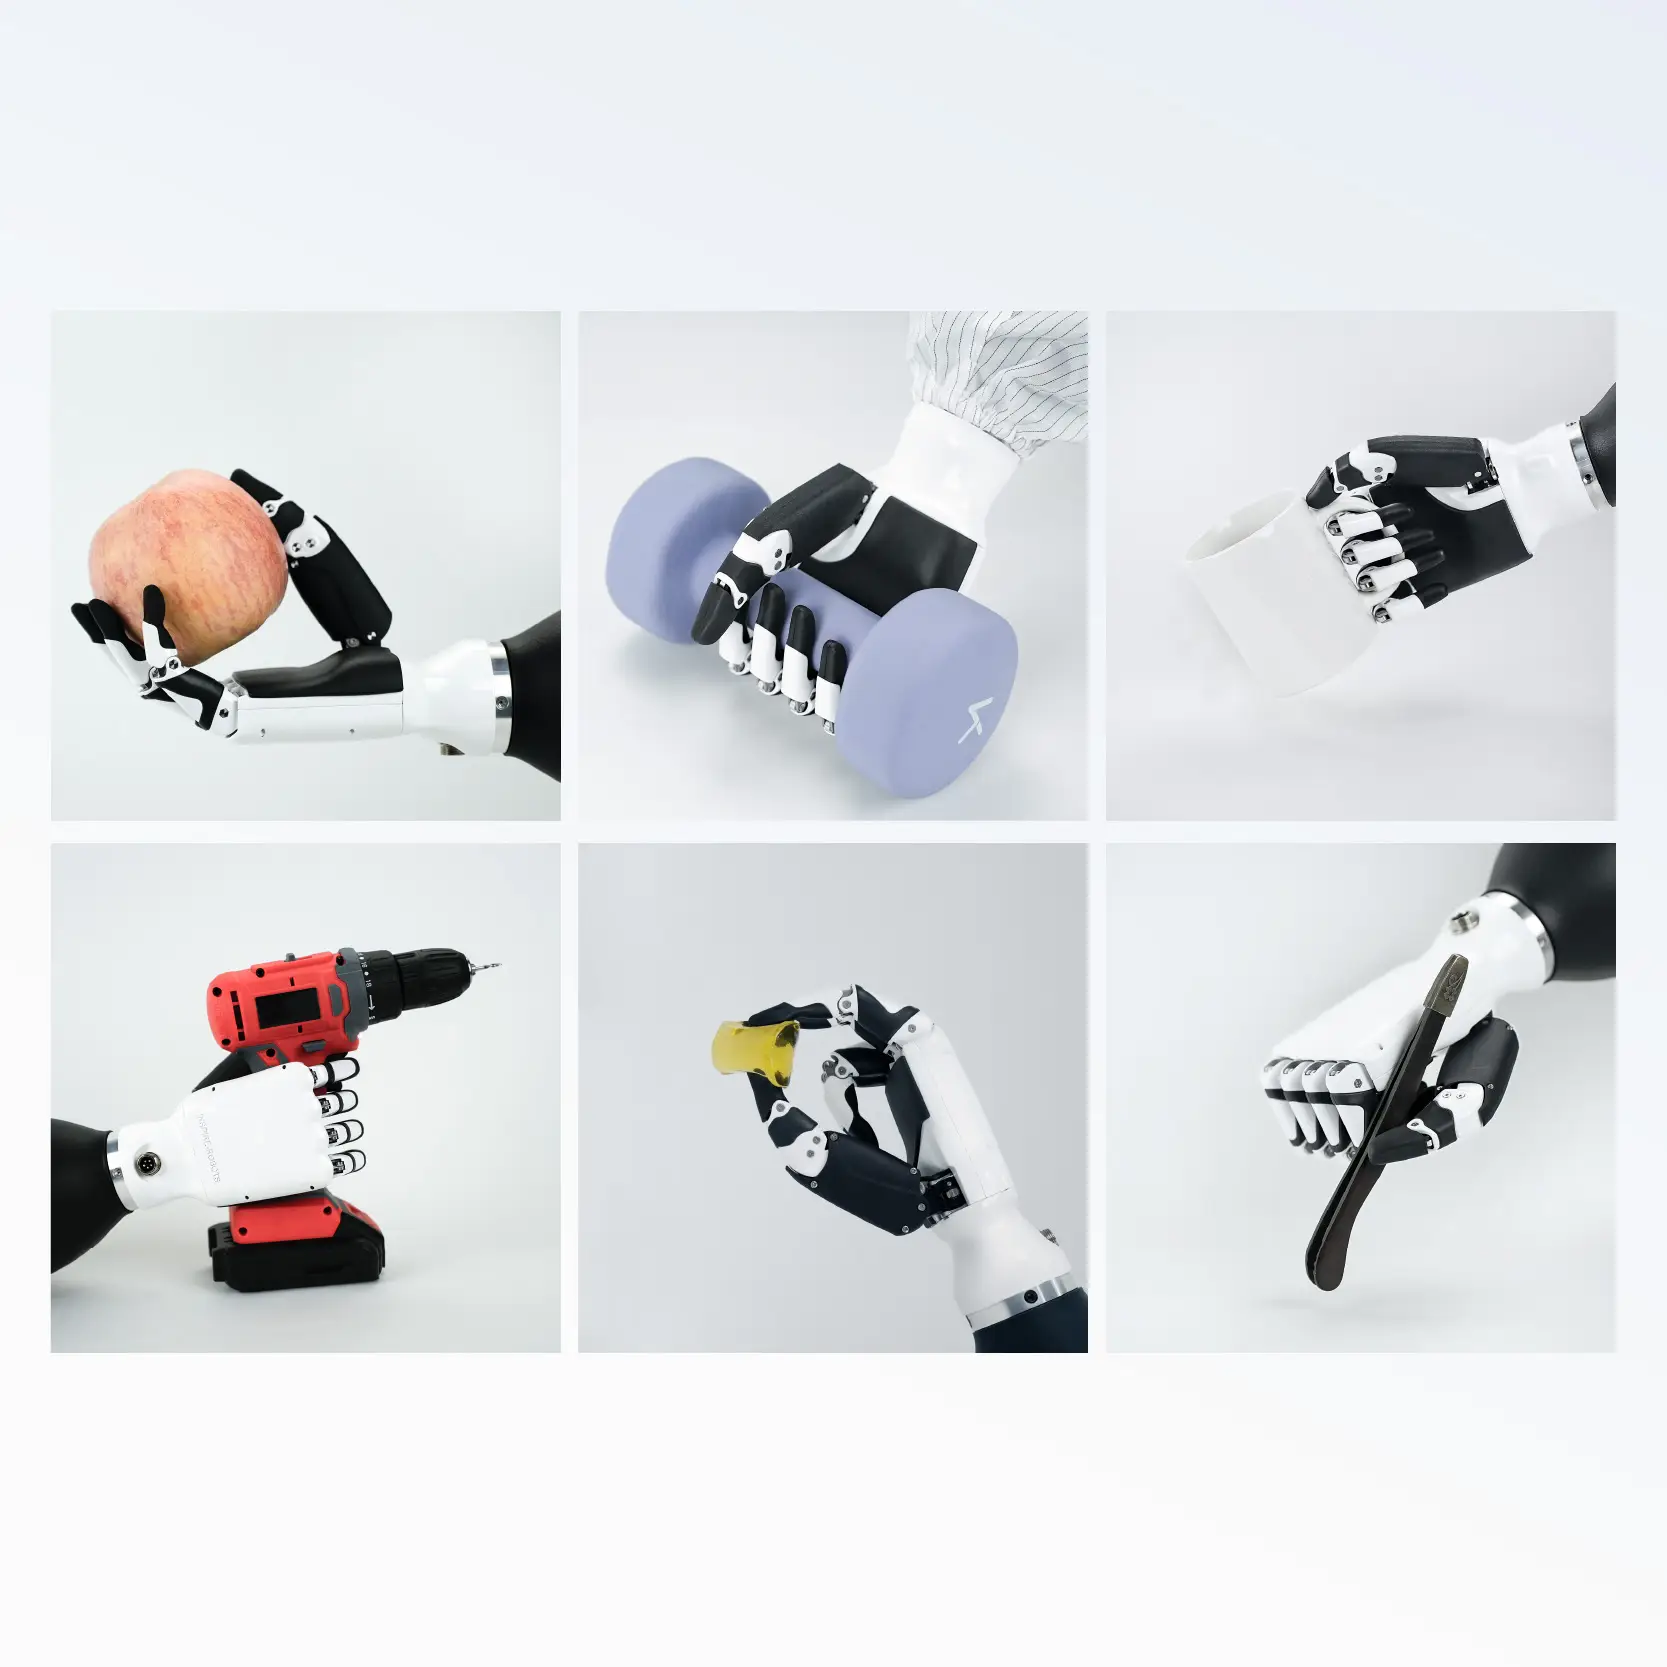
RH56DFX official English product information from INSPIRE ROBOTS.
Standard specifications
| gripper type | Five-finger dexterous hand, RH56DFX family |
|---|---|
| grip force n | Thumb fingertip force 15 N; four-finger fingertip force 10 N |
| finger count | 5 |
| repeatability mm | ±0.20 mm |
| weight kg | 540 g (without wrist); 650 g (with wrist) |
| communication protocol | RS485 |
| supply voltage v | DC 12–48 V |
Technical extensions
Official table: RH56DFX-2L/2R (without wrist) and RH56DFXW-2L/2R (with wrist); 6 DOF / 6+2 DOF, 12 joints; quiescent current 0.09 A / 0.1 A at 24 V; peak current 2 A at 24 V; force resolution 0.50 N; thumb lateral rotation >65° at 107°/s; thumb flexion 70°/s; four-finger flexion 260°/s; wrist yaw ±27° and pitch ±22° on wrist variant; power-off self-locking.